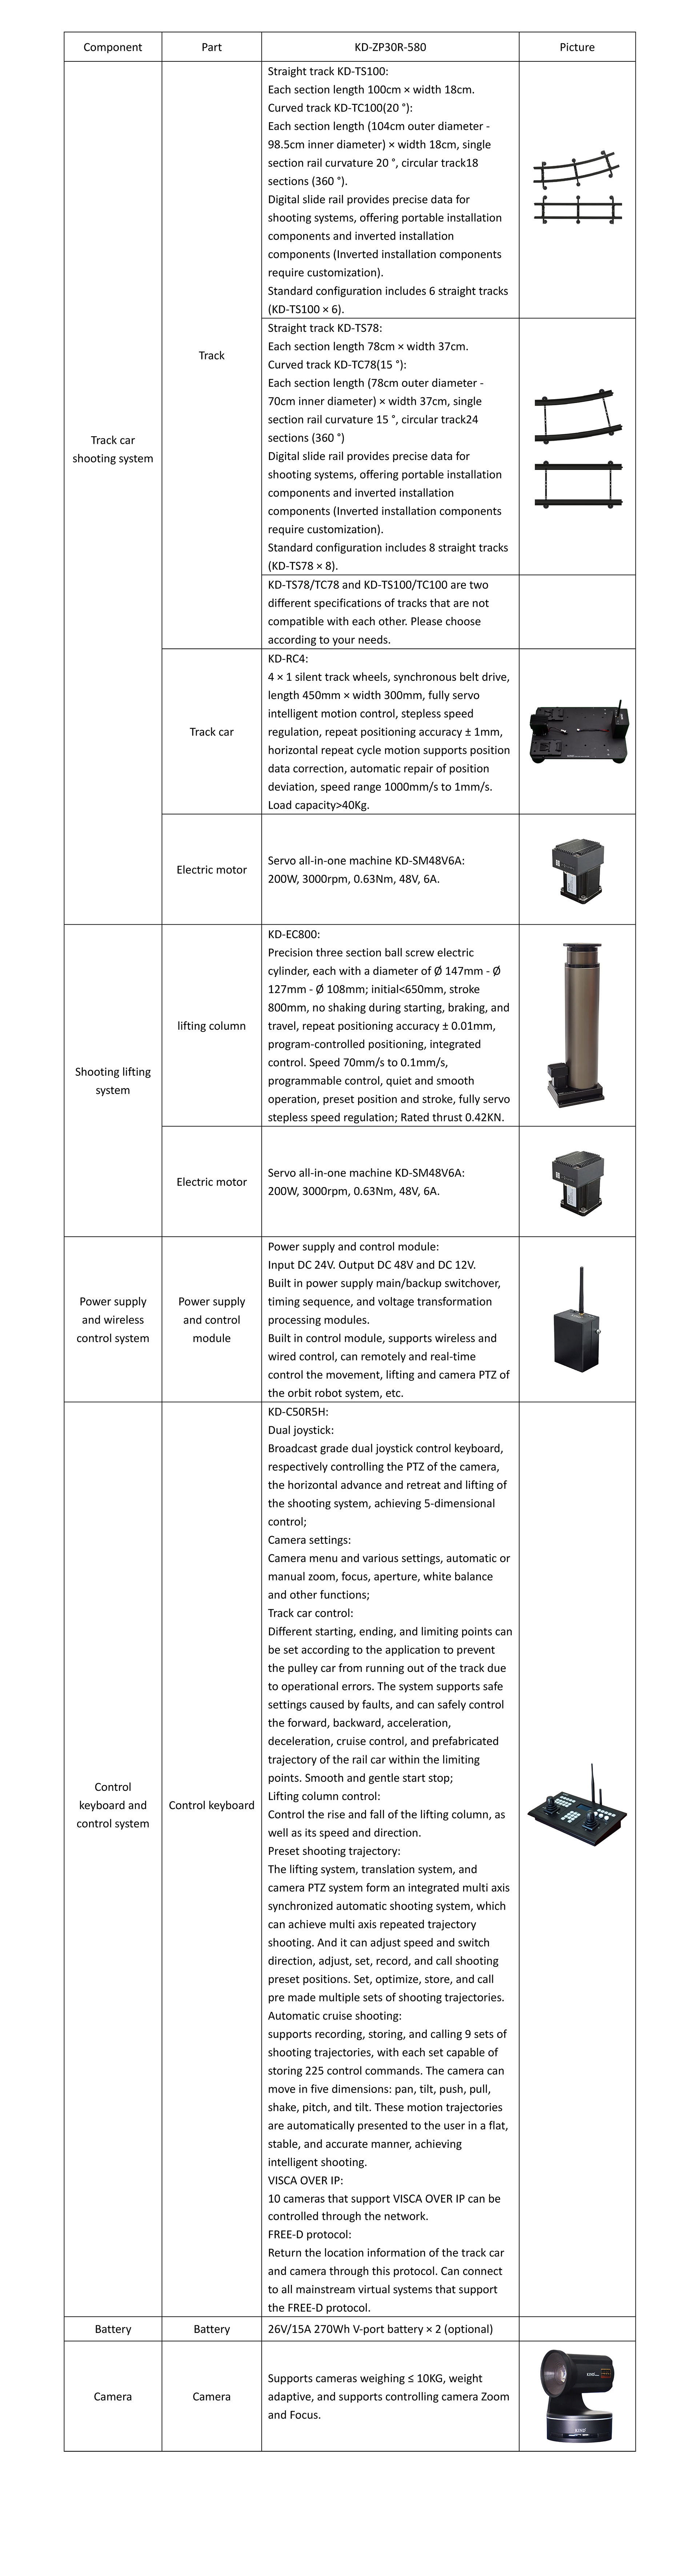


KIND Orbit robot camera KD-ZP30R-580
1 Piece
Product Technical Characteristics
1. The track car and lifting column are both servo systems, with zero point as the reference. The multi axis position and speed of the track car, lifting column, horizontal, pitch, and zoom are controlled by a dual closed-loop system. Accurate position and stable speed, each axis adopts slow stop and slow start technology, making acceleration and deceleration smoother and easier to control.
2. The maximum horizontal movement speed is 1000mm/s, and the maximum lifting movement speed is 70mm/s. Horizontal positioning accuracy ± 1mm, vertical repeat positioning accuracy ± 0.01mm.
3. Vertical stroke 800mm. Rated thrust 0.42KN.
4. Both the battery and adapter can provide power. Dual battery redundant power supply, The battery can be replaced during use.
5. The track car and lifting column are both equipped with 16 speed stages. The acceleration and deceleration time can be adjusted, set through commands, and can be turned off.
6. Provide absolute position commands and continuous position data streams for move/lift, Pan/Tilt, Zoom axis speed or duration parameters.
7. Support uniform and smooth slow cruising motion shooting, eliminating visible speed jumps during slow motion.
8. The instruction speed is 50 instructions per second. The maximum speed of wireless link is 2Mbit/s.
9. Move/Lift, Pan/Tilt, Zoom can independently set speed stages. The movement sequence, speed, and time of each axis can be set. Suitable for different application scenarios and usage habits.
10. The move, lifting, and Pan/Tilt can be independently set in reverse, making it easy to inverted installation.
11. 9 preset points, supporting setting, calling, and deleting.
Preset point call:
Preset point full speed arrival: Move/Lift, Pan/Tilt, Zoom five axis independent motion full speed arrival.
Preset point arrived on schedule: The preset point of the five axis linkage of Move/Lift, Pan/Tilt, and Zoom ensures a smooth transition. The preset point can be called to set the transition duration, and each axis can be slowed in and out simultaneously, supporting A ⇄ B loops and multi-point round-trip sequences. Each segment can be individually set for duration and stay, and can be triggered through the existing USB/serial port command set.
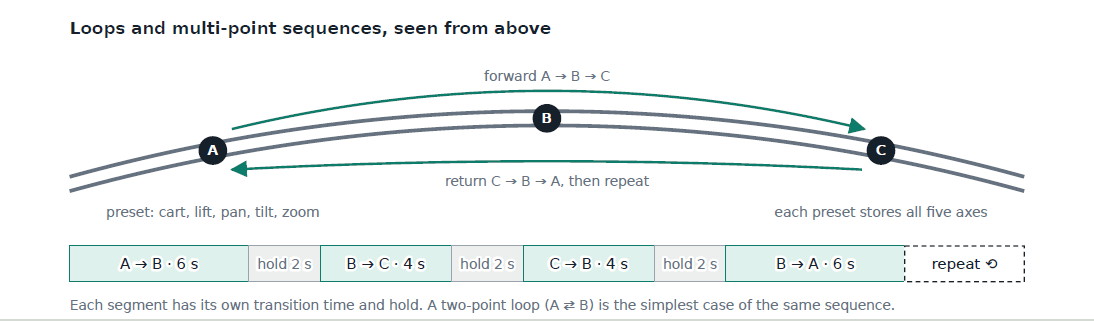
12. 9 preset trajectories, supporting setting, recording, calling, and deleting. Each trajectory supports a maximum of 225 commands. Suitable for complex motion shooting with multiple intermediate positions and carefully arranged, recorded once and replayed as a fixed program segment. Support 1 loop repeated playback.
13. Support Visca protocol (RS232 and RS485), with adjustable baud rates (9600, 115200).
14. Support Visca Over IP protocol and can control the camera through the network port.
15. Support FREE-D protocol. Return the location information of the track car and camera through this protocol. Can connect to all mainstream virtual systems that support the FREE-D protocol.
16. FREE-D uses UDP mode. The port number can be set. Refresh frequency 50Hz.
17. When FREE-D is enabled, serial commands can still be sent through the USB port of the keyboard.
18. Support controlling the SONY camera through the Visco Over IP function of the network port. The FREE-D data of the SONY camera is sent to the control keyboard, which integrates all position information and sends it out uniformly.
19. Provide 50 meter cable. Includes 485 cable, power cable, and 4K60 armored video cable. The RS-485 port of the rail car adopts XS6-4 aviation plug with 4 pins. The maximum length of the line is 100 meters.
Application

Product specification sheet